Definition 7.3.1. An oriented path in is defined to be a path whose restriction to is compatible (non strictly) with the orientation.
7.3.1. Admissible paths
Let be a curve.
Let us note some basics facts about oriented paths.
Properties 7.3.2. Let be a non-constant oriented path in .
- (1)
We have and is contained in the union of the connected components of that have a non-empty intersection with .
- (2)
If is homotopic to a constant path, then it is contained in (as is contractible).
- (3)
There are unique real numbers such that
- –
given , there are with the property that (if ) and (if ) (cf Lemma 7.1.16 for ).
- –
given and such that , we have
- –
given and such that , we have .
The sequence depends only on .
- –
- (4)
Consider homotopy classes of oriented paths , and with . If is contained in but not in , then there are such that , and .
Lemma 7.3.3. Let be a path in . The following conditions are equivalent:
- (i)
lifts to a path in the non-singular cover of
- (ii)
given , given a small open neighbourhood of in and given a connected component of , the set of with is contained in an orbit of .
Proof. Let be the non-singular cover of and be the quotient map.
Assume (i). Consider , , as in the lemma and let be a lift of . Consider with for . We have . Consequently, we have . If and are not in the same -orbit, then and are in distinct connected components of , a contradiction. So, (ii) holds.
Assume (ii). Since lifts of non-identity paths are unique if they exist (Lemma 7.1.20), it is enough to show the existence of lifts locally on . This is clear for a small open neighbourhood of a point of . Consider now and a small open neighbourhood of in . Let be a connected component of and let be the connected component of containing . There is such that . Since splits over , it follows that the restriction of to lifts to . ∎
Definition 7.3.4. We say that a path in is smooth if it satisfies the equivalent conditions of Lemma 7.3.3.
We say that a path in is admissible if it is oriented and smooth.
We say that a homotopy class of paths is smooth (resp. admissible, resp. oriented) if it contains a smooth (resp. an admissible, resp. an oriented) path.
Let us note some basic properties of smooth and admissible paths and classes.
Properties 7.3.5.
- (1)
A path is smooth if and only if its inverse is smooth.
- (2)
A smooth path is contained in a component of .
- (3)
Every admissible path is homotopic to a minimal admissible path via a homotopy involving only admissible paths contained in the support of (cf Lemma 7.1.18).
- (4)
A minimal path in a smooth (resp. admissible) homotopy class is smooth (resp. admissible).
- (5)
An oriented path is admissible if and only if its homotopy class is admissible (Lemma 7.1.16 provides a minimal oriented path homotopic to a given oriented path with the property that is admissible if is admissible, hence we obtain the desired equivalence by (4) above).
- (6)
Given two oriented homotopy classes of paths and with admissible, then and are admissible (cf (5) above).
Definition 7.3.6. Given two smooth non-identity homotopy classes of paths and contained in the same component of , there is a unique such that there is a minimal smooth path in with the property that and are equal to the classes of restrictions of . We say that and have the same orientation (resp. opposite orientation) if (resp. ).
Note that and have the same smooth paths. Note also that the notion of “opposite orientation” does not depend on the orientation of .
Remark 7.3.7. Assume is obtained by the construction of Remark 7.2.5. A homotopy class of paths in is smooth if and only if it contains a path such that the composition is a smooth immersion.
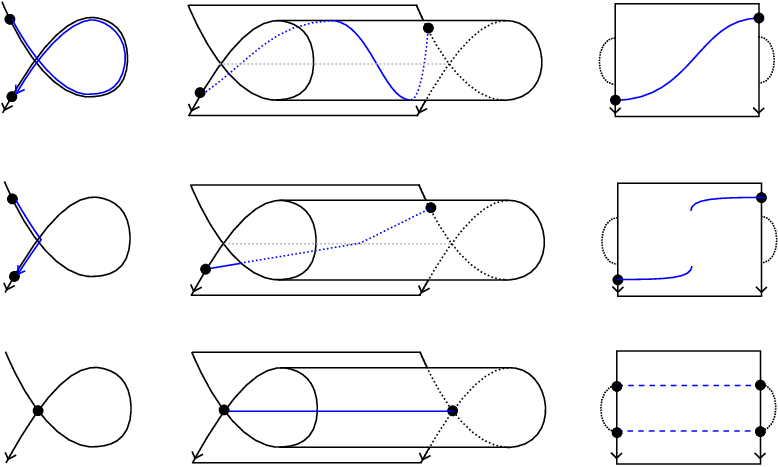
Example 7.3.8. We give below some examples of paths. The top and bottom paths are admissible, while the middle one is not. The left and middle columns describe the path in the singular curve, while the right column describes the lifted path (if it exists) in the non-singular cover.
In the middle and right columns, and throughout the paper, we depict paths using their time-reversed graphs, so that is on the right and is on the left.
 |
Original source: arXiv:2009.09627v2