Proposition 7 If plane diagrams and represent isotopic oriented links, these diagrams can be connected by a chain of moves I-IV.
4.1 Reidemeister moves
Given a link in we can take its generic projection on the plane. A generic projection is the one without triple points and double tangencies. An isotopy class of such projections is called a plane diagram of or, simply, a diagram. The following four types of transformations of plane diagrams preserve the isotopy type of the associated link.
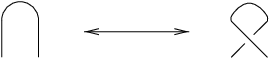
I. Addition/removal of a left-twisted curl:
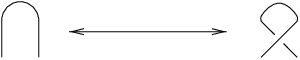
II. Addition/removal of a right-twisted curl:
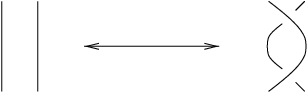
III. Tangency move:
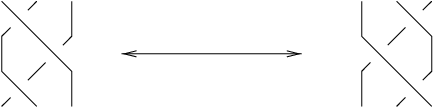
IV. Triple point move:
Original source: arXiv:math/9908171v2