2.4 Kauffman bracket
In this section we review the Kauffman bracket and its relation to the Jones polynomial following Kauffman [Ka]. Fix an orientation of the 3-space . A plane projection of an oriented link in is called generic if it has no triple intersections, no tangencies and no cusps. In this paper by a plane projection we will mean a generic plane projection. Given a plane projection we assign a Laurent polynomial to by the following rules
- 1.
A simple closed loop evaluates to
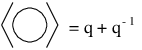
- 2.
Each over and undercrossing is a linear combination of two simple resolutions of this crossing:
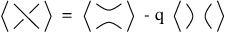
- 3.
where stands for the disjoint union of the diagrams and
From these rules we deduce that
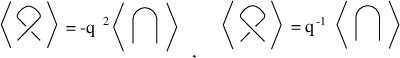
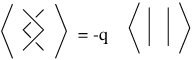
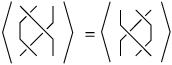
Curves of the diagram inherit orientations from that of Let be the number of double points in the diagram that look like

and the number of double points that look like

Then the quantity
| (21) |
does not depend on the choice of a diagram of the oriented link and is an invariant of We denote this invariant by Up to a simple normalization, is the Kauffman bracket of link and equal to the Jones polynomial of The Kauffman bracket, as defined in [Ka], is a Laurent polynomial in an indeterminate (this has no relation to the algebra in Section 2.2 of this paper). One easily sees that setting our to and dividing by we get :
| (22) |
In this paper we will call the scaled Kauffman bracket.
Let and be three oriented links that differ as shown below.
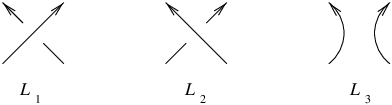
The rules for computing the Kauffman bracket imply
| (23) |
Moreover, if is the unknot.
The Jones polynomial of an oriented link is determined by two properties:
- 1.
The Jones polynomial of the unknot is
- 2.
For oriented links as above
(24)
Therefore, the scaled Kauffman bracket and the Jones polynomial are related by
| (25) |
Original source: arXiv:math/9908171v2